Safety & setup
Risk assessment, work cells, emergency stops, payloads, tooling and coordinate frames.
Industrial Robots
Move from safe setup and coordinate frames to planning, simulation, controllers, and complete C++ with ROS 2 integrations.
Start learning
310 lessons, eight modules.
Start with Module 01 and work through at your own pace.
Start Module 01The fleet
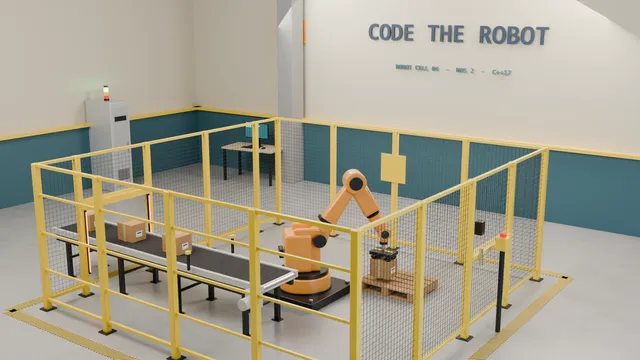 Module 01 · 40 lessonsSix-Axis Articulated Arm
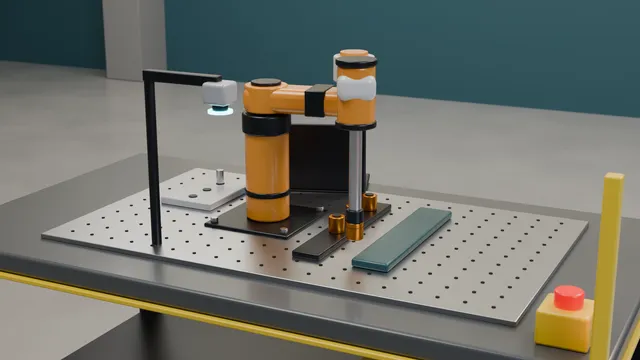 Module 02 · 30 lessonsSCARA Robot
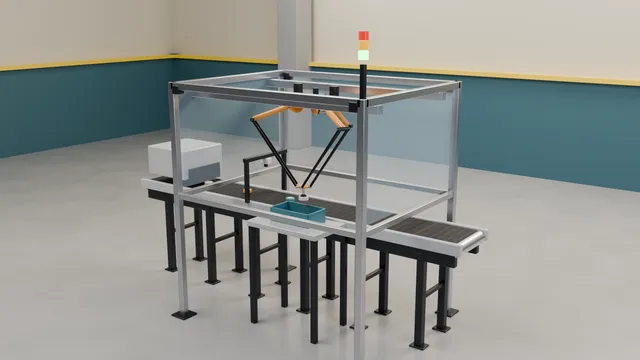 Module 03 · 30 lessonsDelta Parallel Robot
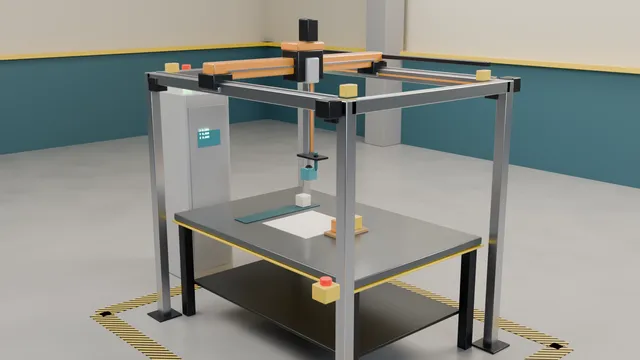 Module 04 · 25 lessonsCartesian Gantry Robot
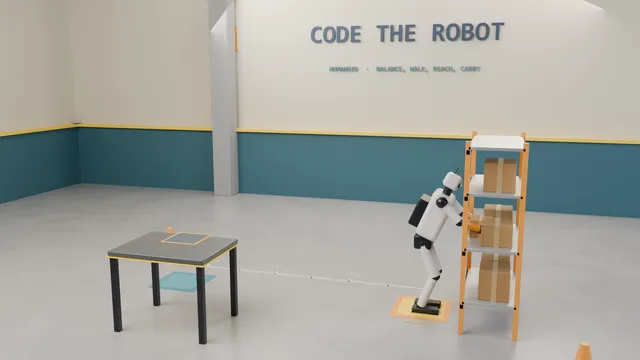 Module 05 · 40 lessonsHumanoid Platform
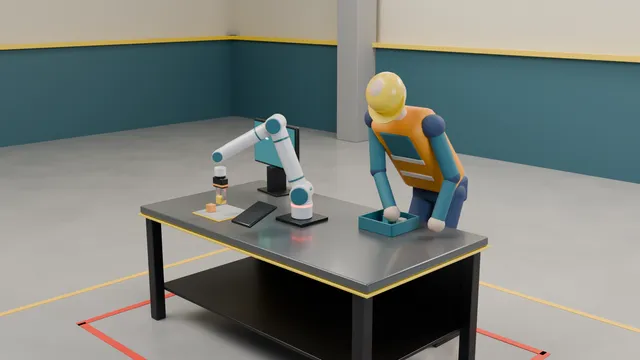 Module 06 · 30 lessonsCollaborative Robot (Cobot)
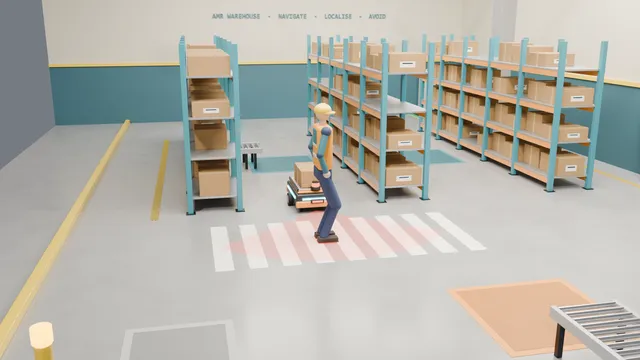 Module 07 · 40 lessonsAutonomous Mobile Robot (AMR)
 Module 08 · 75 lessonsAutonomous Drone (PX4 + ROS 2)
Risk assessment, work cells, emergency stops, payloads, tooling and coordinate frames.
Forward and inverse kinematics, trajectories, collision-aware planning and controller tuning.
Drivers, hardware interfaces, actions, diagnostics, simulation and repeatable deployment.
Course lessons
Every lesson has a concept, guided steps, a code example with a note under each line, an exercise and a checklist.
Foundations
Motion & Control
End-Effectors & I/O
Geometry & Kinematics
Assembly & Precision
Parallel Kinematics
High-Speed Applications
Linear Kinematics
Industrial Applications
Kinematics & Dynamics
Perception
Locomotion & Manipulation
Safety & Interaction
Control & Applications
Kinematics & Perception
Mapping & Navigation
Warehouse Logic
Ubuntu for Drone Developers
C++17 for Flight Control
ROS 2 Lyrical Luth for Drones
PX4 Autopilot
MAVLink
Offboard Control with ROS 2
Drone Perception
Drone Navigation