Module 01 · 40 lessons
Six-Axis Articulated Arm
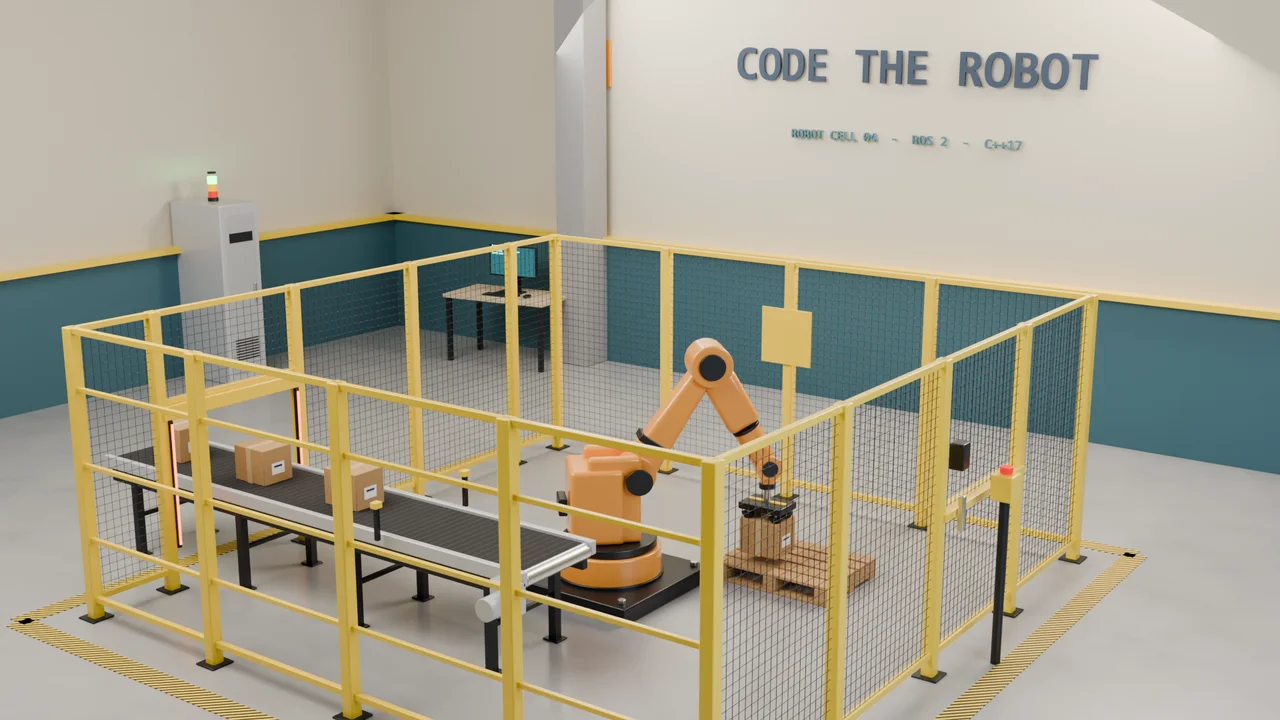
MODULE 01
6-AXIS CELL
Foundations
- 01Robot anatomy & joint types
- 02Coordinate frames (world, base, tool)
- 03DH parameters introduction
- 04Forward kinematics derivation
- 05Inverse kinematics analytical methods
- 06Numerical IK solvers
- 07Workspace & reach analysis
- 08Singularities & avoidance
- 09Joint limits & safety envelopes
- 10Tool center point (TCP) calibration
Motion & Control
End-Effectors & I/O
Software & ROS 2